

Read More


Recognized for AI Excellence at 2026 Globee® Awards - Read More

Nihar Raval
Conventional OEMs still take 40 to 50 months to move a vehicle program from kickoff to software release, while newer entrants complete a full vehicle in 24 to 30 months, according to McKinsey. The gap has little to do with talent. Software architecture, development tools, and release processes increasingly determine how quickly automakers can bring new vehicles and features to market. With the code behind a vehicle's ECUs reaching up to 100 million lines, automotive software development has become the main constraint on time to market, certification and margin per vehicle across support windows that exceed ten years.
For buyers evaluating partners that build automotive software, the useful question is less about language choice and more about how a team handles integration, compliance, and over-the-air updates. Service providers who build automotive solutions while keeping the fundamentals of scalable software development and those who layer in safety evidence on top are the ones who can help you go to market faster and also absorb late requirement changes with far less costly rework.
Automotive software development is the engineering of embedded, connected and safety-critical code that controls how a vehicle drives, protects occupants and updates after sale. It follows a V-model process under ISO 26262 and ASPICE, relies on AUTOSAR, simulation and HIL testing, and costs roughly $60,000 to $2 million or more depending on safety rating and integration depth. Partner choice, based on safety-process maturity, decides delivery speed and rework.
| Aspect | Details |
|---|---|
| What does this guide cover? | Automotive software types, V-model process, ISO 26262 compliance, toolchains, challenges, cost, partner selection, and future connected and electric vehicle trends. |
| Who should read this guide? | OEM product leaders, Tier-1 supplier executives, startup founders building mobility products, CTOs, engineering heads, fleet technology teams, and procurement managers evaluating software vendors. |
Software now decides how a vehicle drives, how it protects occupants, and how much revenue it earns after the sale. The role of software in automotive industry programs has moved from supporting single components to coordinating behavior across powertrain, chassis, safety, infotainment and connectivity.
Automotive software development is the process of designing, building, testing, and maintaining software used in vehicles and their connected systems. It includes embedded control systems, advanced driver-assistance systems (ADAS), infotainment, telematics, vehicle connectivity, and software-defined vehicle capabilities.
A mid-range car already runs dozens of ECUs, and premium or electric models pass a hundred. Consolidation into domain and zonal controllers is changing how that code gets structured.
Over-the-air (OTA) updates add a commercial angle; an OEM can fix defects, ship features and monetize functions after delivery, which turns software from a cost line into a product line. OEMs and Tier-1 suppliers, thus, increasingly look for automotive-specific software engineering expertise, which covers vehicle-level constraints and release pipelines, not just coding capacity.
The commercial logic is easy to see in procurement. Software now accounts for a growing share of vehicle bill-of-materials value, and feature differentiation has moved from the showroom floor to the update calendar. A buyer comparing two vehicles in 2026 is often comparing release cadence and interface quality, not horsepower.
Investment is accelerating, but quality is not keeping pace. The automotive software market was valued at $35.37 billion in 2025 and is projected to reach $144 billion by 2035, yet 30 to 40% of vehicle recalls now involve software-related issues (MarketGrowthReports, 2026).
OEM priorities reflect the same shift. IoT Analytics' December 2025 SDV adoption report found that 45% of OEMs rank software-defined vehicles as their top strategic priority, ahead of ADAS (25%) and the EV transition (14%).
The architecture underneath matters more than the headline. Traditional vehicles run 70 to 100 distributed ECUs, each tied to one function, so changing a function means changing the hardware it runs on.
Software-defined vehicles move to centralized or zonal compute, where functions run as independent services and update over the air. That makes one question unavoidable before scoping begins; will the system be updated after deployment, or fixed at launch?
Retrofitting OTA into a system that was not designed for it needs partial re-architecture, which adds months and budget after the original go-live date.
The key features of automotive software stay consistent across programs:
Software is now the product, not a component inside it. Programs that treat it that way plan architecture, safety and release cadence together from day one.
Vehicle software falls into three groups. Control software (ECUs, ADAS, powertrain), experience software (HMI, navigation, infotainment) and operations software (diagnostics, fleet, telematics). Each group carries different safety, latency, and certification demands.
Controls engine, transmission, braking and battery behavior. It is written mostly in C/C++ on AUTOSAR, runs on real-time operating systems and carries the strictest safety requirements in the vehicle.
Covers sensor fusion, perception, path planning and intervention logic for functions like lane keeping and emergency braking. Perception stacks increasingly rely on machine learning for driver assistance features, which raises validation effort, since model behavior has to be proven across edge cases rather than assumed.
The layer between driver and vehicle, covering clusters, center displays, voice and touch. Android Automotive OS, QNX and Linux-based stacks dominate. Latency and driver-distraction rules matter more than visual polish.
Goes well beyond turn-by-turn routing. Production systems combine map data, live traffic, charging availability and range estimation, then sync with the cloud to learn routes.
Reads fault codes over CAN and UDS, supports remote diagnosis and feeds predictive maintenance models. Workshops use it for repair, while OEMs mine the field data for recurring defects.
Aggregates telematics, driver behavior, fuel and maintenance data. Operators with mixed fleets get the most from fleet management software with tracking and scalability. Such platforms plug into dispatch and ERP instead of living in a separate dashboard.
Take a Note- Two categories deserve a mention even though they cut across the list above. Telematics control units connect the vehicle to backend services and carry most of the data flow, while security software (secure boot, intrusion detection, key management) now ships as a baseline layer in every domain controller rather than an optional add-on.
Most programs touch four or five of these at once, so integration planning belongs in the first sprint, not the last.
Embedded software puts decision-making inside the vehicle, close to sensors and actuators. The payoff is faster response, tighter safety control and lower running costs, none of which cloud-only systems can match.
Well-built automotive software development solutions compound these gains because every ECU share data instead of working in isolation. The advantages that show up in program reviews:
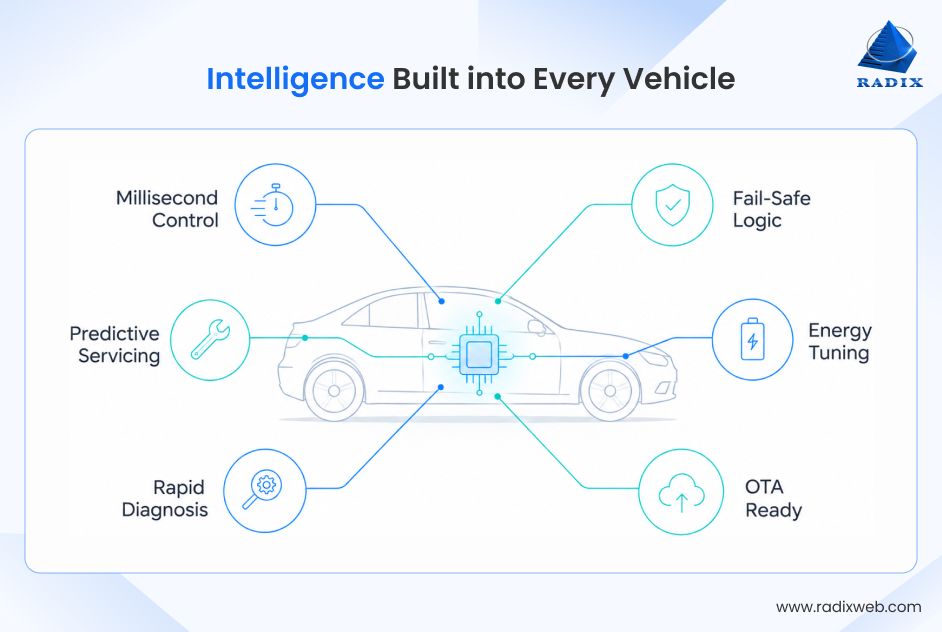
Braking, stability control, and airbag logic run in milliseconds on the device, with no network dependency. Because the logic runs locally, a dropped connection or congested network cannot delay a safety-critical decision, which is why control functions stay onboard while analytics move to the cloud.
Redundancy, watchdogs and fail-operational modes sit in the control layer, which supports ISO 26262 certification. Safe states are defined for every failure mode, so a faulty sensor or crashed process degrades the function gracefully instead of leaving the driver without control.
Condition-based maintenance replaces fixed service intervals. For haulage and distribution operators, where fuel and downtime dominate spend, connected solutions for freight and logistics operators turn that vehicle data into route, fuel and uptime decisions.
Powertrain and battery control software tunes torque, regeneration and thermal management on the fly. Calibration improvements can reach vehicles already on the road, so efficiency keeps improving after delivery, which matters for EV range and fleet fuel spend.
Embedded diagnostics pinpoint the failing component, which cuts workshop hours. Stored fault codes with freeze-frame data show the conditions around a failure, which reduces repeat visits and no-fault-found repairs.
Software-defined functions can be added through OTA rather than new hardware. Features that once needed a hardware revision, such as new driver-assistance behavior or a refreshed interface, can ship as software, which extends how long a platform stays competitive.
Teams that track warranty cost per vehicle or feature attach rate, not just story points, end up tying engineering priorities to business outcomes far more reliably. Embedded capability only pays off when the process around it keeps pace, and that is where most programs slip.
The steps to developing automative software are pretty much the same as that of developing any other type of software. What differs is what actually happens during those steps. The automotive software development process follows a V-model.
Requirements and design on the left, verification and validation on the right, with every design level tied to a matching test level. Agile practices now sit on top for feature work, while safety-critical components keep the formal gates.
Every program runs on an automotive software development life cycle defined by ASPICE and ISO 26262, with traceability from requirement to test evidence. The automotive software development workflow inside that frame usually runs like this:
Start with the basics of software architecture design, which includes freezing scope, allocating functions to ECUs, defining interfaces, and setting safety goals. McKinsey puts the ideal requirements to freeze roughly two years before final release, since late changes are the costliest defects in a program.
Simulink or SysML models get simulated early (model-in-the-loop) before any code exists. Early simulation exposes logic errors and requirement gaps while they are cheap to fix, and the same models can generate code and seed the test cases used later.
Hand-written C/C++ under MISRA rules, plus code generated from models. Static analysis runs on every commit, and generated code goes through the same review, and coverage checks as hand-written code, so quality gates do not depend on who or what wrote it.
Strong automotive software integration merges modules across ECUs and buses (CAN, LIN, Ethernet, SOME/IP), validated on software-in-the-loop and hardware-in-the-loop rigs. Each integration between new and existing systems brings its own timing, protocol and interaction effects, so integration testing needs its own budget line, and the validation suite should be built before development starts, not during it.
Coverage metrics, safety cases, cybersecurity, and type-approval evidence. HIL validation is a mandatory step for safety-critical systems, and ASIL-D demands 100% MC/DC coverage, which takes structured test engineering rather than functional QA alone.
The final step includes OTA delivery, monitoring, and incident response. A production-grade OTA pipeline needs cryptographic signing of every package, staged rollout to fleet subsets, A/B partitions for failsafe rollback, and post-update telemetry to catch regressions. This makes ongoing software maintenance a must-have, not just a nice-to-have.
Note: The UNECE R156 requires a Software Update Management System (SUMS), but it is an architecture requirement during development, not a post-launch document, so plan accordingly.
Key Takeaways for TeamsGate reviews deserve more attention than they usually get. A requirement that passes design review but lacks a defined test case will resurface during homologation, when fixing it costs the most. Strong programs attach a test method to every requirement at the moment it is written, and they track coverage as a release metric.Pure waterfall no longer fits feature software, and pure Scrum rarely satisfies a safety audit. Hybrid delivery wins. V-model gates for safety-relevant components, two- to four-week sprints for infotainment, apps and cloud services, and CI/CD pipelines feeding both.Selecting a software development methodology is thus, something that needs to happen before contracts are signed.A process runs only as fast as its slowest feedback loop, so the toolchain behind it decides how much of this holds in practice.
Toolchains in this field are shaped by safety standards: certified compilers, static analyzers, model-based design environments, and simulation rigs. Languages are mostly C and C++, with Python, Kotlin and, increasingly, Rust around the edges.
| Category | Tools and technologies |
|---|---|
| Languages | C/C++ for ECUs (under MISRA rules), Kotlin and Java for Android Automotive, Python for tooling and ML, Rust for memory-safe components |
| Architecture standards | AUTOSAR Classic for deterministic ECUs, AUTOSAR Adaptive for high-performance compute |
| Operating systems | QNX, Automotive Grade Linux, Android Automotive OS and certified RTOS options |
| Modeling and simulation | MATLAB/Simulink, dSPACE, Vector CANoe and CARLA for ADAS scenarios |
| Testing and analysis | VectorCAST, Polyspace, Coverity and HIL benches |
| Requirements and ALM | Polarion, DOORS and Jira with traceability plugins |
| DevOps | GitLab or Jenkins pipelines, containerized build farms and virtual ECUs for cloud-based testing |
Connected features depend on more than just the onboard code. Telemetry ingestion, edge gateways and vehicle-to-cloud security draw on connected vehicle sensors and telemetry engineering, with streaming platforms like Kafka and cloud analytics handling the data layer. Planned, resilient IoT integration enables secure data exchange and real-time vehicle insights.
Qualification is the part buyers usually underestimated. Under ISO 26262, the compiler, code generator and test harness all need a qualification argument before they touch ASIL-rated code, and vendors that ship pre-qualified kits save weeks of paperwork.
Tool choice should follow the certification target, not preference, since a qualified toolchain is far cheaper than retrofitting qualification evidence.
Most delays trace back to five causes. Variant sprawl, slow integration, hardware-software timeline mismatch, compliance load, and supplier opacity. Each has a fix that works when applied early.
McKinsey notes that the portfolio complexity gap between conventional OEMs and new entrants can reach a factor of 150, measured by models offered.
Solution: Product-line engineering, shared platforms and feature toggles replace per-model branches.
Stabilizing changes to communication signals between ECUs can take more than 20 weeks.
Solution: Virtual ECUs and SIL testing let integration start before hardware exists, backed by strict change control on the communication matrix.
Hardware runs on three- to seven-year cycles while software iterates in weeks.
Solution: Service-oriented architecture and zonal compute decouple the two, so features update without hardware revisions. Programs that formalize choosing between plan-driven and iterative delivery per subsystem avoid forcing one cadence on every team.
ISO 26262, ISO/SAE 21434 and UNECE R155/R156 all demand evidence.
Solution: Pipelines should generate that evidence continuously instead of assembling it before auditing.
Suppliers sometimes ship binaries without source, which leaves OEMs blind on change effort and weakens negotiation.
Solution: Code and IP ownership belong to the contract at architecture stage.
Engineers who combine embedded, safety, and cloud skills are scarce.
Solution: Stable cross-functional teams, with partner capacity for peak load, hold up better than constant hiring.
One pattern repeats across troubled programs. Teams treat each cause as a separate workstream, then discover that a change in one area breaks another.
A frozen communication matrix, for instance, only holds if supplier interfaces are fixed at the same time. And the virtual testing only pays off if the models mirror the real ECU behavior closely enough to trust the results.
Fixes work best in combination. Virtual testing without clean requirements just finds the same problems faster.
Most projects land between $60,000 and $2 million or more, depending on safety rating, integration depth and certification scope. A standalone diagnostics tool or fleet dashboard sits at the low end, while ASIL-rated ECU or ADAS work sits at the top. Multi-domain SDV platforms sit above that range, starting at $3 million.
| Scope | Typical range | Typical timeline |
|---|---|---|
| Focused tool (diagnostics app, fleet dashboard, companion app) | $60K to $150K | 3 to 5 months |
| Connected platform (HMI, cloud backend, OTA) | $150K to $500K | 6 to 10 months |
| OTA update infrastructure (signing, rollback, SUMS) | $200K to $700K | 8 to 14 months |
| Safety-critical component (ECU, ADAS, ASIL B to D) | $500K to $2M+ | 12 to 24 months |
| Full SDV platform (multi-domain) | $3M+ | 24 to 48 months |
These are indicative ranges for outsourced engagement. The actual cost of building software will move with scope and team location.
Four drivers explain most of the variance: -
Budget talks go better when, what CTOs should settle before building is answered up front, build versus buy, platform ownership and who carries certification risk.
The right automotive software development engagement models map to scope stability: -
Rates vary by region and seniority, but they explain less of the final number than buyers expect. A senior safety engineer costs more per hour and still lowers total spend when that person catches an architecture flaw before it spreads across five ECUs.
Cost overruns in this field rarely come from rates. They come from late requirement changes and rework in integration.
Whether or not you find the right software development company to build your solution is often the difference between systems that launch and scale and those that fail beyond pilots and demos.
When looking at vendors for automotive software development, pick teams based on safety-process maturity and integration track record, not just developer headcount or tech stacks. An automotive software developer who has shipped through ASPICE gates is worth more than three who have not.
Custom software development for automotive industry work differs from enterprise delivery in how much evidence, traceability and hardware proximity it requires. Screen for these points:
Ask for the failure stories too. A partner that can describe a missed integration milestone has usually learned more than one whose case studies contain no setbacks at all. Reference calls with the engineering lead, not the account manager, surface this quickly.
A paid pilot of six to eight weeks on a real integration problem tells you more than any proposal. Watch how the team handles an ambiguous requirement.
The vehicle is becoming a software platform on wheels. Fewer, more powerful computers, continuous OTA delivery and revenue models tied to features rather than hardware. Programs that plan for that now avoid expensive re-architecture later.
Five automotive software trends already show up in RFPs:
Dozens of ECUs collapse into a handful of high-performance computers, which shifts work toward platform software and middleware. Zonal controllers handle local I/O and power distribution near the sensors while central computers run the heavy functions, which also cuts wiring harness weight and cost.
AI-assisted requirements, code generation, and automated testing will rise. Inside the cabin, perception, driver monitoring and voice are growing fastest, as covered in where AI already works inside vehicles.
Containerized builds, digital twins and virtual validation shorten cycles. Virtual ECUs and digital twins let teams run regression tests in parallel in the cloud, so validation no longer waits for scarce bench hardware.
OTA turns software into recurring revenue, and it raises the bar on update safety. Subscription features need entitlement management, secure activation and clear rollback paths, since a failed unlock or a bad update becomes a customer-facing issue.
A group of 11 automotive companies recently signed a memorandum to co-develop open-source vehicle software, aiming to cut duplicated effort. AUTOSAR Adaptive Platform membership grew 22% in the past year, and the Eclipse SDV working group now counts over 50 members developing open standards. So the ecosystem is consolidating faster than many procurement timelines assume.
Navigating the Automotive ShiftThe talent model shifts alongside the architecture. Platform teams, application teams and a vehicle-integration function now replace the old supplier-per-ECU split. OEMs that keep architecture and integration in-house while partnering on feature delivery tend to scale better than those that outsource everything or nothing.Electric and connected vehicles add another layer. Battery management, thermal control, charging protocols such as ISO 15118 and OCPP, V2X messaging and energy-aware routing. Teams planning EV programs should review the software requirements specific to EV platforms early, since battery and charging logic influence the whole architecture.

Begin Your Journey Towards Automotive Software Development
Cost is only the starting point of any automotive software decision. Instead of fixating a single number, understand how the software is built, the safety rating, the integration surface, the test infrastructure, and the compliance evidence. So, when speaking with custom software engineering service providers, focus on how they explain their estimates and which variables move them. Armed with that, you can judge proposals more realistically.With two and a half decades of software engineering experience, Radixweb can turn those variables into a practical development plan. Schedule a consultation with our team for a custom estimate covering cost, timeline, deliverables, and roadmap, so you understand the number behind the quote and have a clear path from planning to release.
Ready to brush up on something new? We've got more to read right this way.

